
FS25 Realistic Harvesting V1.6.4.0
Realistic Harvesting for FS25 adds dynamic harvesting physics based on crop density, cutting width, moisture, engine load, machine calibration, and yield efficiency. It supports grain combines, forage harvesters, root and vegetable harvesters, cotton, and sugarcane.
Features
- Physics-Based Engine Load & Speed: Ground speed dynamically adapts based on harvested crop mass (t/h), header width, and vehicle horsepower. Overloading the engine or using incorrect settings results in real grain loss.
- All Machine Types Supported: Fully calibrated physics for Grain Combines, Forage Harvesters (chaff/silage), Root & Vegetable Harvesters (potatoes, beets, carrots, parsnips, spinach, peas), Cotton, and Sugarcane.
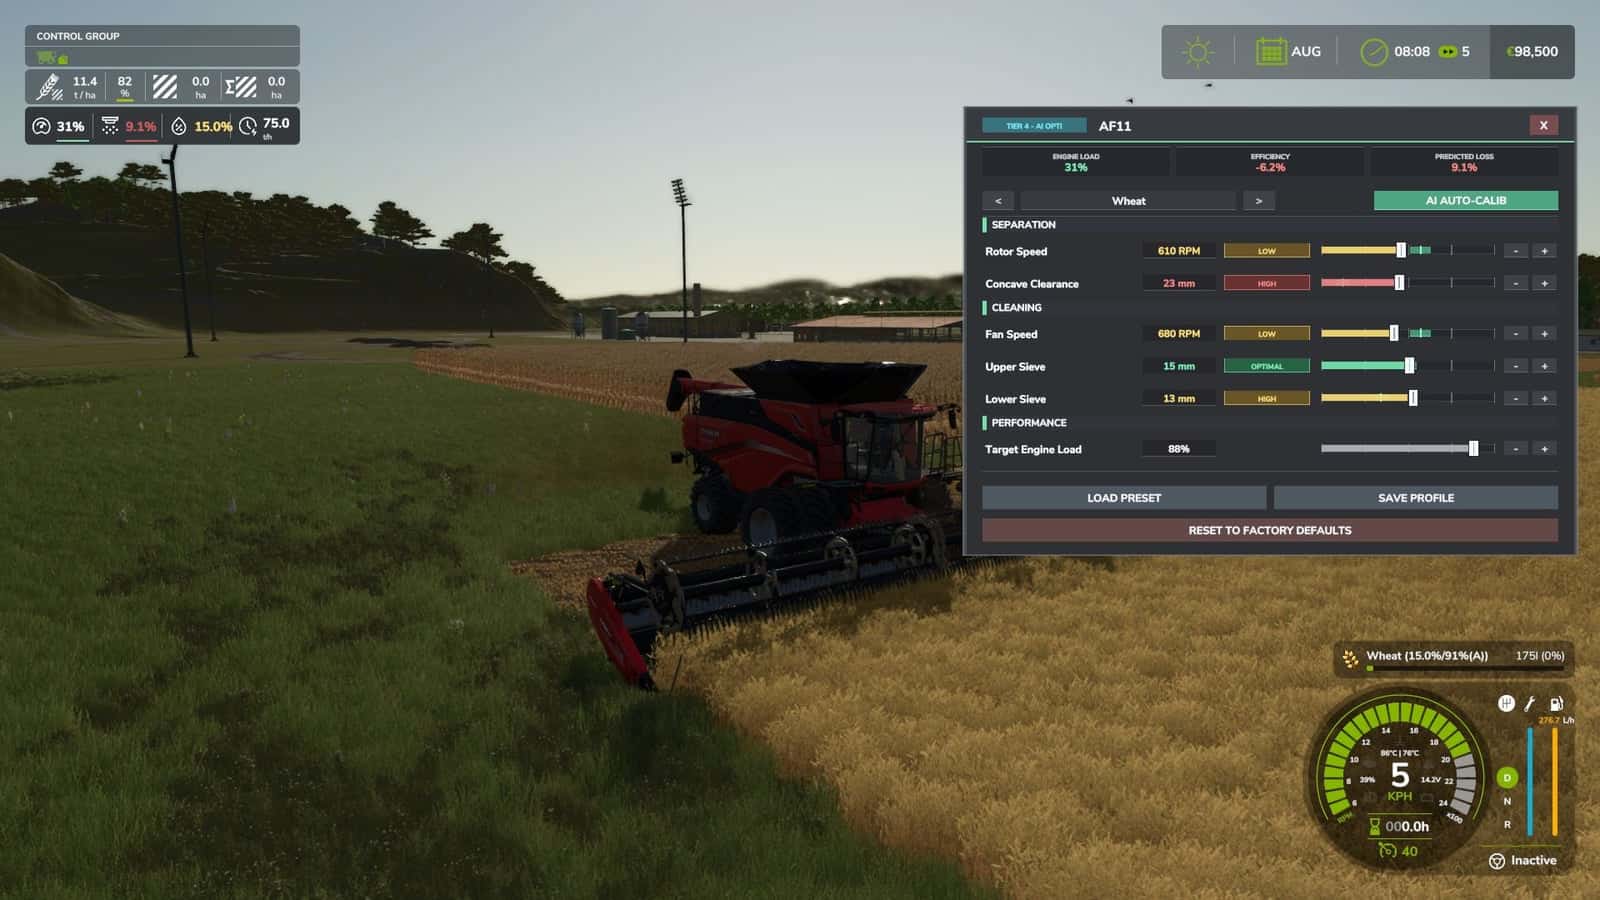
- Interactive Combine Calibration: Use
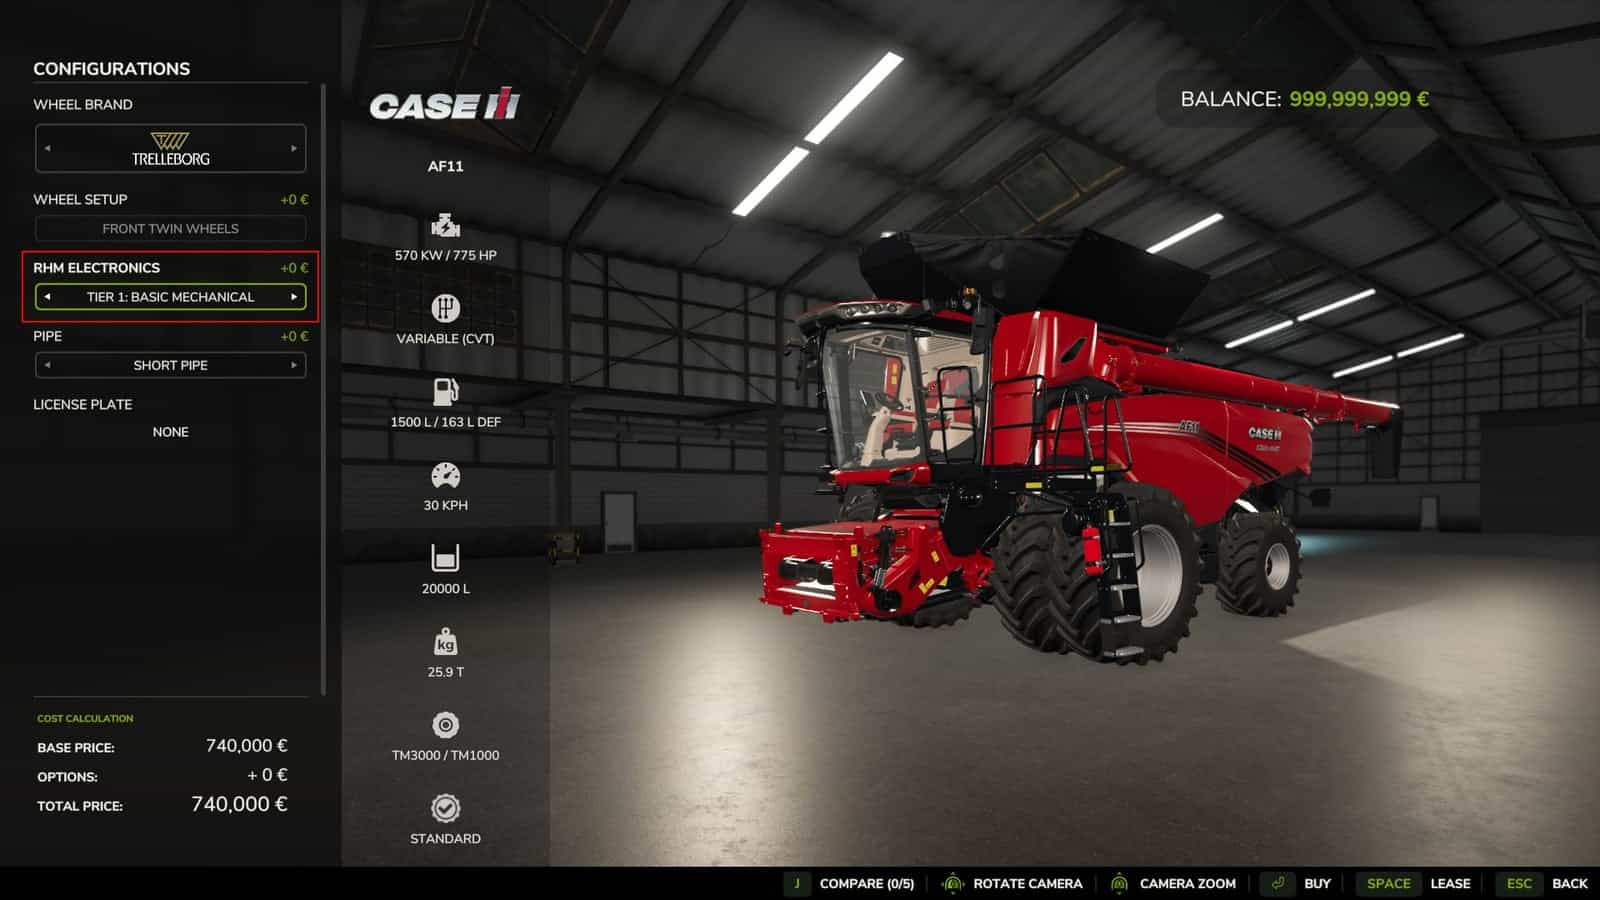
RShift + Kto calibrate Rotor/Drum RPM, Concave Clearance, Fan Speed, and Sieves for each crop. Correct settings ensure maximum yield and minimum loss. - Workshop Upgrade Packages, Tiers 1-4: Upgrade your combine at the shop.
- Level 1 (Standard): Fully manual operation.
- Level 2 (Sensor Kit): Displays calibration guidance hints (low / optimal / high).
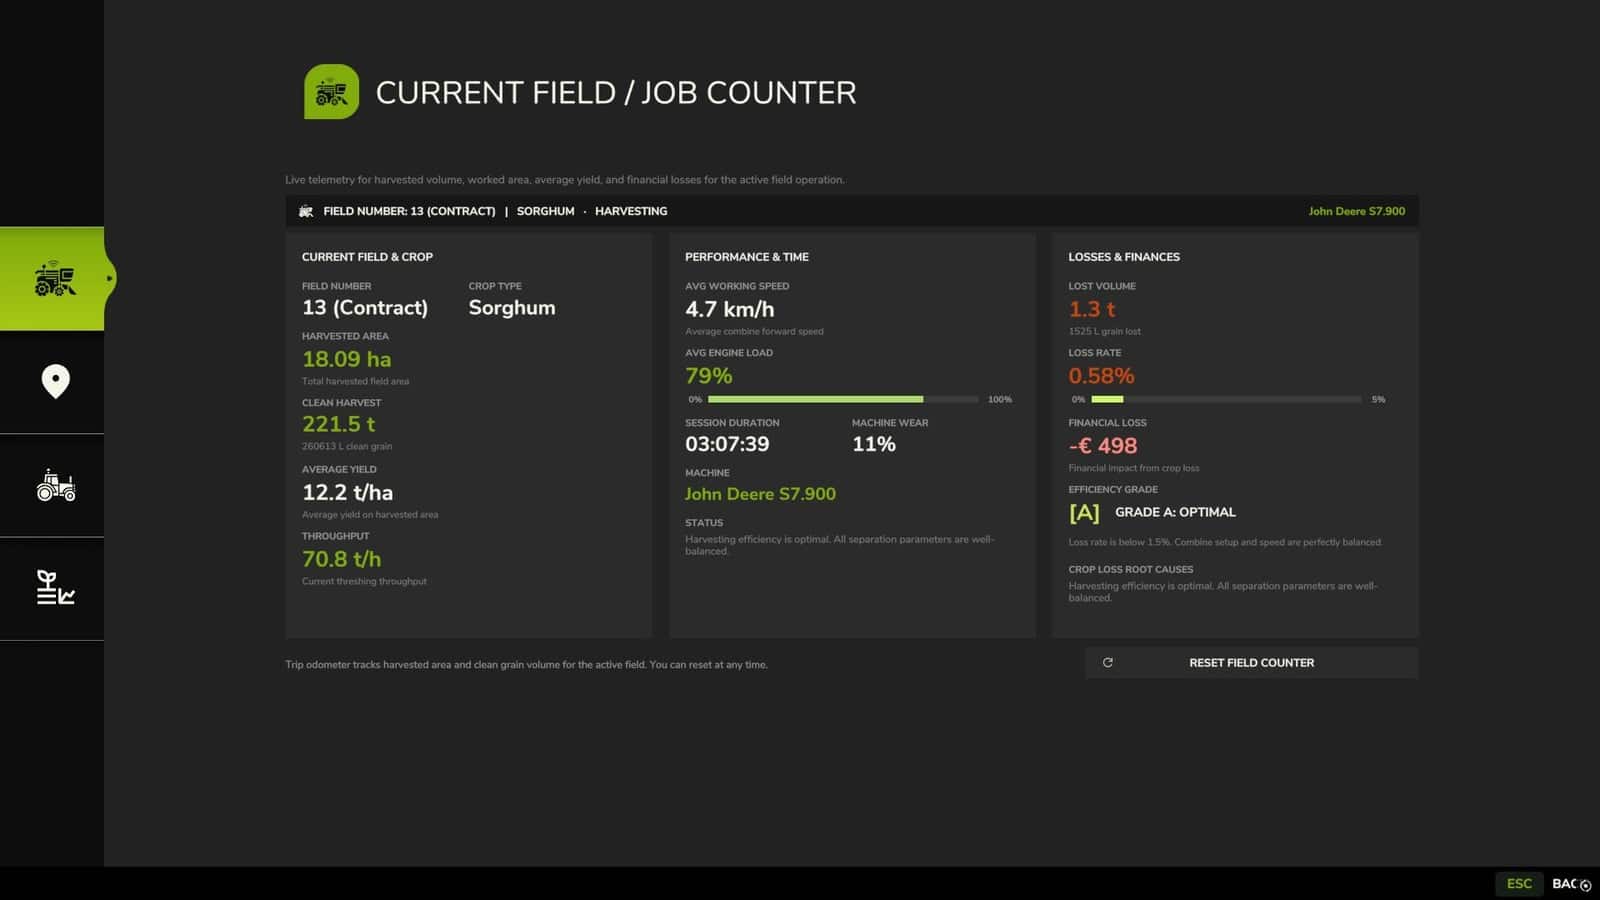
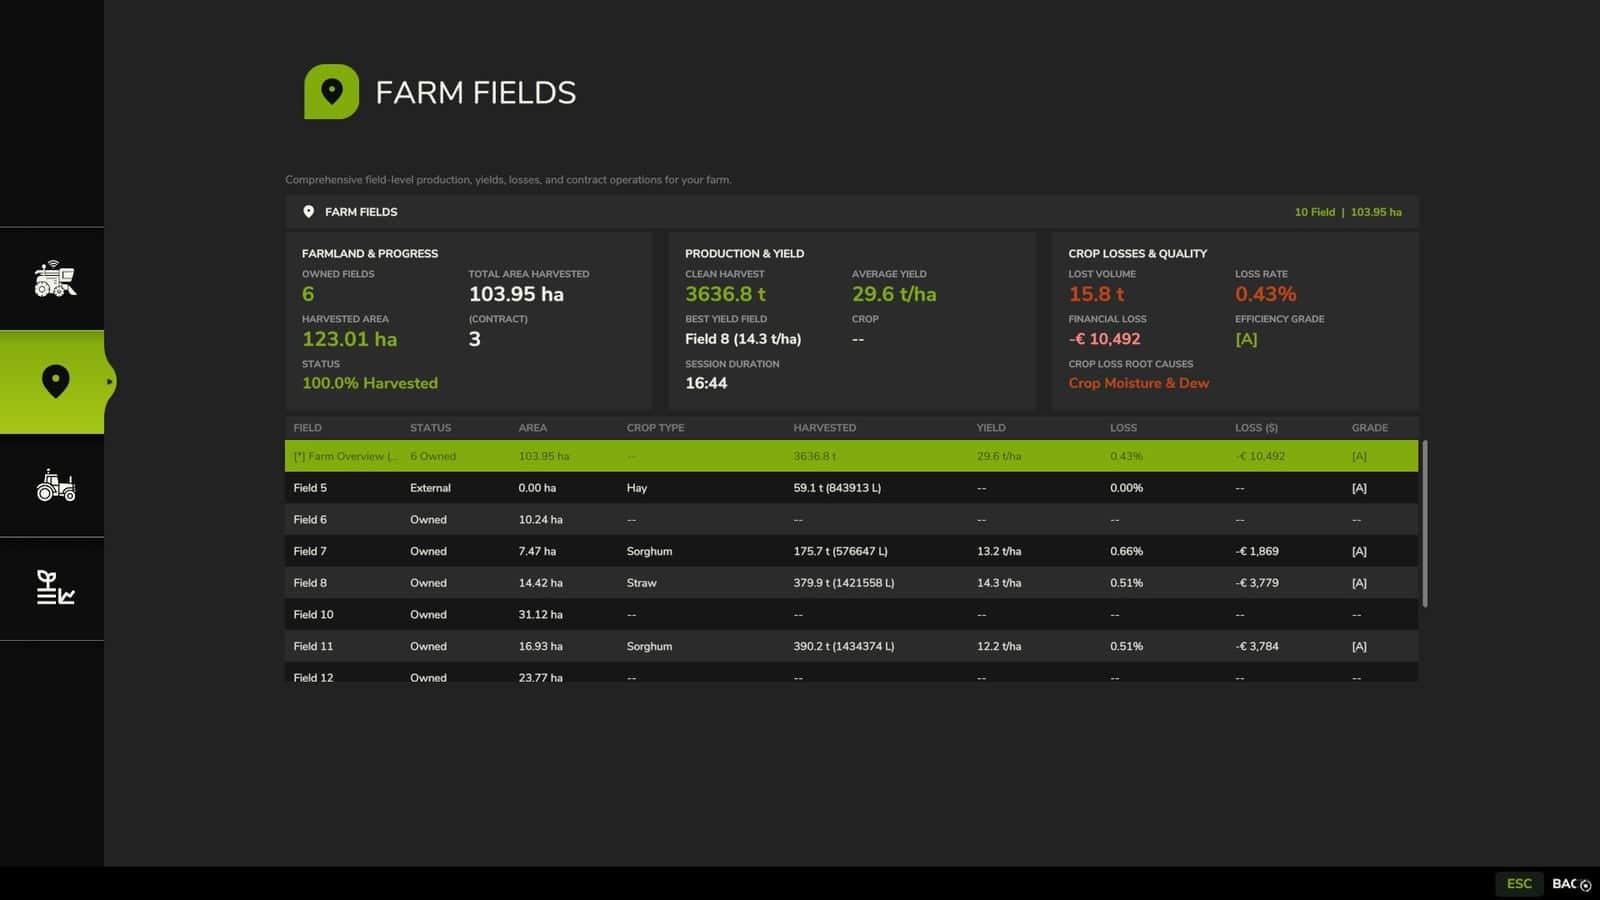
- Level 3 (Yield Monitor): Real-time yield (t/ha, bu/ac), area rate (ha/h), and moisture telemetry.
- Level 4 (Opti-Harvest AI): Automatic settings calibration and automated speed management.
- AI & Courseplay Compatibility: AI helpers and Courseplay workers automatically utilize your saved profiles or optimal calibrations.
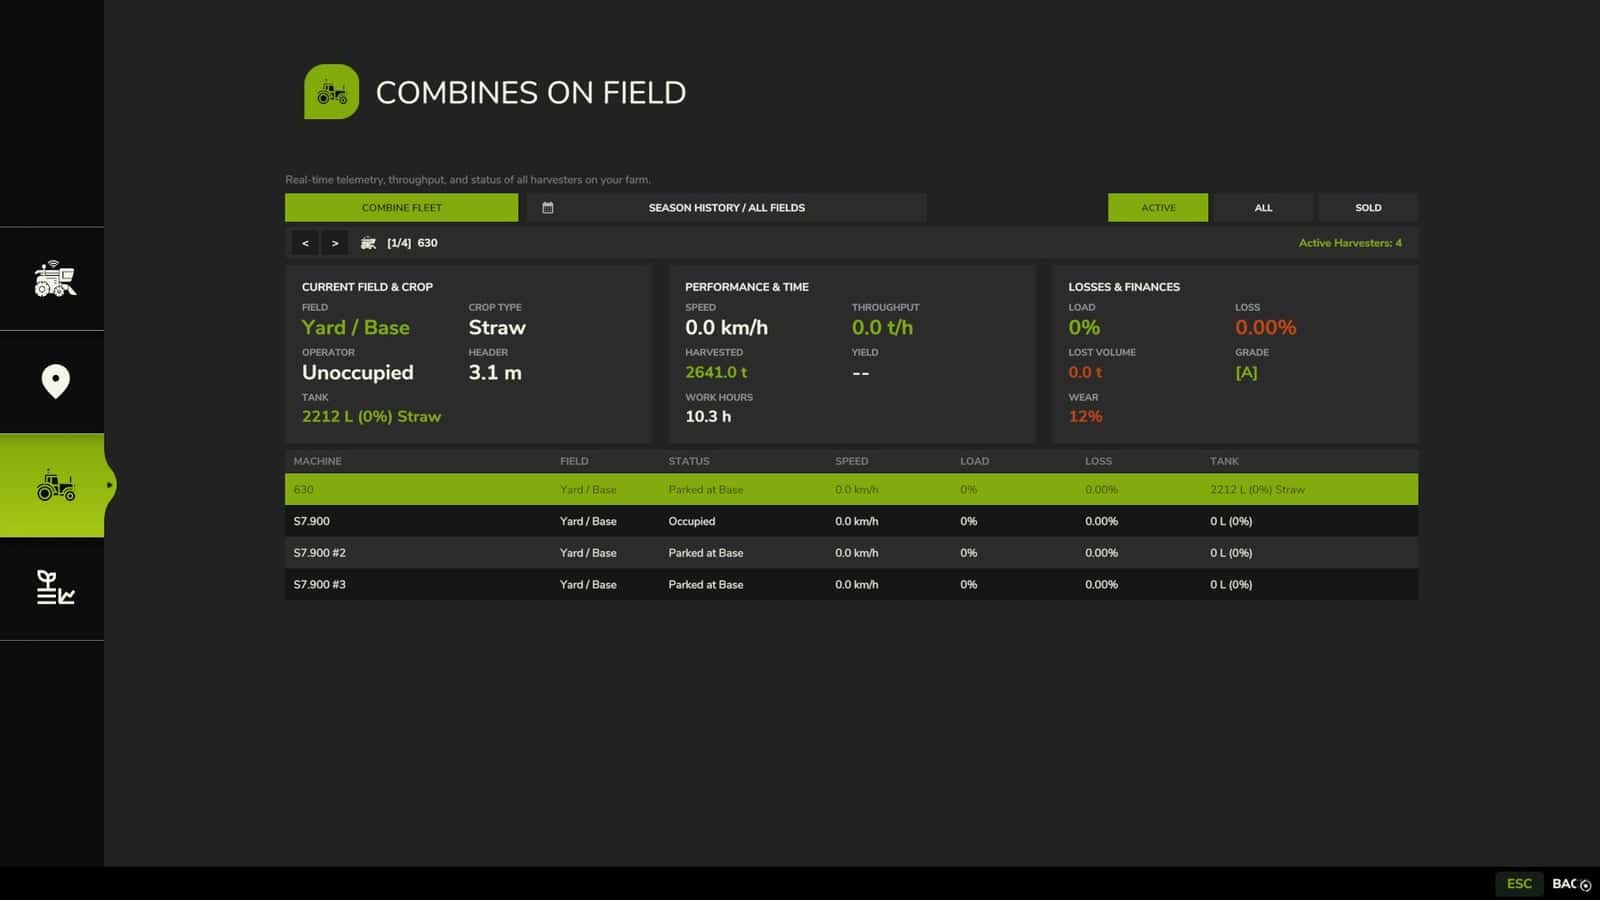
- Draggable HUD: A movable on-screen display showing live Engine Load, Productivity (t/h, ha/h), Crop Loss %, and Moisture.
- Global Crop Profiles: Save your favorite tuning once. Profiles automatically load across your combines and savegames.
- 3 Difficulty Modes (ESC Settings): Choose between Arcade (relaxed), Normal (balanced), or Realistic (strict physical limits and penalties).
V1.6.4.0
New Features
- Threshing Mechanism Classification System: Implemented an automated classification engine in
rhm_Combine.luathat classifies harvesters into 6 mechanical categories based on vehicle XML data, wheel count, and chassis dimensions. STRAW WALKER, conventional straw walker combines.AXIAL ROTOR, single and dual longitudinal rotor systems.HYBRID APS, accelerator pre-separation cylinder with twin separation rotors.FORAGE CHOPPER, precision-chop drum and accelerator systems.ROOT HARVESTER, lifting shares, sieving webs, and cleaning rollers.SPECIALTY, cotton, sugarcane, grape, and olive harvesters.- Added a real-time Threshing System Indicator badge to the Shift+K calibration terminal header.
- Added public API endpoint
RHM_Api.getThreshingType(vehicle). - Added localized naming across all 27 language files (
translations/l10n_*.xml). - 3-Way HUD Work Rate & Productivity Monitoring: Implemented interactive click-cycling in Yield Monitor HUD Cell 7 (expanded layout) and Cell 4 (compact layout).
- Cycles between: Processed Area (ha / ac) <-> Instantaneous Work Rate (ha/h / ac/h) <-> Session Average Work Rate (ha/h / ac/h).
- Added session average work rate telemetry to the Trip Statistics frame.
- Added public API method
RHM_Api.getAverageHectaresPerHour(vehicle).
Improvements & Optimizations
- Native GIANTS Engine 10 Cutter Specialization: Migrated cutter logic into an official GIANTS Engine 10 vehicle specialization (
rhm_Cutter), completely replacing runtime monkey-patching ofCutter.onLoad. - Registered
<specialization name="rhm_Cutter" />inmodDesc.xmland dynamically injected it across all cutter vehicle types. - Differentiated Power Balance and Moisture Physics: Differentiated base driveline drag according to threshing architecture: 8.0% for straw walkers, 9.5% for hybrid APS, 11.0% for axial rotors, 10.0% for root harvesters, and 9.0% for forage harvesters.
- Refactored moisture processing drag in
RHM_LoadCalculator.lua: straw walkers receive an exponential resistance penalty in damp, clumped straw mats, whereas rotary systems maintain steady crop flow with lower specific moisture resistance. - Differentiated moisture separator loss rates across mechanism types.
- Multiplayer Telemetry Synchronization: Added high-frequency network stream replication (
onWriteUpdateStream/onReadUpdateStream) for burned fuel, average speed, average engine load, all 5 loss breakdown reasons (speed, settings, moisture, wear, slope), and concave clearance. - GUI & Telemetry Responsiveness: Reduced analytics and trip refresh loops to a 250ms cadence with explicit open/close reset handlers, resolving frozen telemetry values.
- Upgraded throughput monitoring to simultaneously display instantaneous peak and session average throughput (t/h).
Bug Fixes
- Modular Carrier & Gantry Combine Support: Resolved an issue where harvesters mounted as detachable modules on motorized gantry carriers displayed zeroed HUD telemetry and failed to record odometer trip data.
- Implemented zero-allocation implement tree traversal (
rhm_Combine.getAllAttachedCutters) to discover cutters attached directly to the carrier chassis. - Updated cutter working width calculations, weed biomass sampling, cruise speed regulation, wear loss calculations, and field tracking across modular equipment configurations.
- Crab-Steering & Diagonal Motion Handling: Fixed false-positive reverse detection on vehicles equipped with crab-steering, all-wheel steering, or wide-span travel modes where local chassis Z-vector displacement is non-positive despite forward directional velocity and active crop intake.
- Ensured active crop flow acts as an immediate bypass for motion direction validation.
- Cutter Lowering & Working State Detection: Fixed an issue where rigid, non-hydraulic implement attachers failed the recursive
getIsImplementChainLoweredcheck. - Switched cutter lowered validation to direct implement state (
cutter:getIsLowered(true)) with direct joint check fallback. - Added a carrier ground speed fallback in
RHM_DraggableHUD.luawhen an attached combine module reports < 0.2 km/h due to decoupled root nodes. - Engine Crash Guard & Dedicated Server Permissions: Added strict type validation (
type(flag) == "number") prior to invokingvehicle:raiseDirtyFlags(flag), preventing native enginebit32.borcrashes. - Fixed Dedicated Server permission validation in
RHM_Settings.luaby evaluatingg_currentMission:getHasAdminRights()alongsideg_currentMission.isServerAdmin.
V1.6.3.2
- Headland Speed Governing: Fixed an issue where harvesters remained speed-locked at harvesting crawl speeds (5 km/h) during headland turns. Lifting the header now immediately releases the motor to full maneuvering speed (15-20 km/h).
- Implement Chain & Hydraulic Verification: Prioritized authentic feeder house hydraulics (getJointMoveDown, getIsImplementChainLowered) over unfolded header states (Foldable:getIsLowered), preventing wide and draper headers from falsely reporting a lowered cutting state when lifted.
- Dedicated Server Live Telemetry Sync: Replaced unsupported bitwise operations with native GIANTS Engine 10 methods, fully restoring real-time network stream replication for engine load, throughput (t/h), yield, and recommended speed on multiplayer clients.
- Automated Helper Synchronization: Added synchronized header start/stop for helpers when separate header launch is active, and resolved live driver handover telemetry resets.
V1.6.3.0
Combine Physics & Powertrain Dynamics Physics